
Mujoco
MuJoCo simulates general-purpose physics involving multiple joints and contact dynamics.
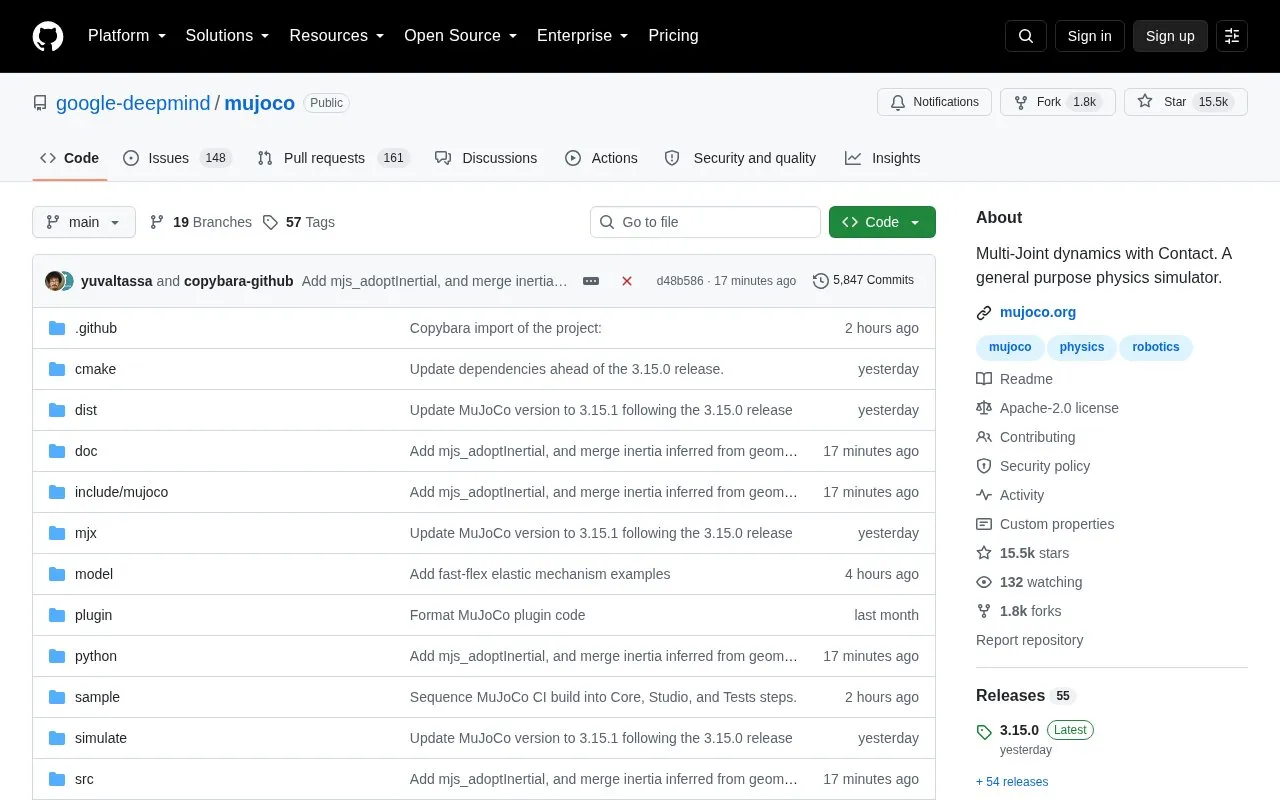
About Mujoco
MuJoCo, short for Multi-Joint dynamics with Contact, is a general-purpose physics engine for fast and accurate simulation of articulated structures that interact with their environment. The repository states that it is intended to support research and development in robotics, biomechanics, graphics and animation, machine learning, and related areas. It is maintained by Google DeepMind and is open source.
MuJoCo has a C API aimed at researchers and developers. Its runtime works on preallocated low-level data structures built by an XML compiler, and it includes a native interactive viewer rendered in OpenGL. Python bindings and a Unity game engine plug-in are also provided. Prebuilt binaries are available for Linux, Windows (x86-64 only), and macOS, and the Python package can be installed from PyPI.
Key features
- Simulates articulated multi-joint structures interacting with their environment through contact dynamics
- C API with a runtime tuned for performance on preallocated data structures
- XML compiler that builds the model data structures used at runtime
- Native interactive viewer, called simulate, with OpenGL rendering
- Python bindings installable from PyPI with pip
- Unity game engine plug-in, plus tutorial notebooks on Google Colab
- Runtime is tuned to maximize performance, according to the repository
- Prebuilt binaries are provided for Linux, Windows, and macOS, and are the recommended installation method
- Python bindings come pre-packaged with MuJoCo and install with a single pip command
- The C API is intended for researchers and developers rather than general users
- Windows binaries are available for x86-64 only
- The commit at the tip of the main branch may be unstable
Mujoco at a glance
- Category
- Education & Learning › Science Learning
- Type
- Open-source project
- Pricing
- Not confirmed. Check the site
- Open source
- Yes · Source code
- Language
- English
- Last checked
- Oct 6, 2026 · Online when checked
- Listed
- Oct 5, 2026
Popular in Science Learning
Well-known listings from the same topic.


Mujoco FAQ
How can I get started with MuJoCo?
How do I install the Python bindings?
Where should I report bugs or ask questions?
Tell us and an editor will check it.
Claim the listing and suggest updates yourself. An editor checks every claim first.